LeWorldModel — Two-Room Baseline Reproduction
Reproducing the official LeWM (JEPA + SIGReg) Two-Room planning benchmark on Apple Silicon · June 3, 2026 · companion to pusht-baseline.html
Bottom line. Running the genuine le-wm/eval.py dataset-replay protocol
(50 episodes, seed 42, official CEM) against the released quentinll/lewm-tworooms checkpoint
on Apple Silicon (MPS) reproduces the paper's Two-Room result: 86.0% (43/50) — within ~1 point
of the paper's ~87 and close to an independent reporter's 90. This is the second
of the paper's four worlds we've reproduced (after PushT, 90%), and it required
no new fixes — the exact setup from PushT carried over verbatim.
1 · Task-completion results
Two-Room is a 2D navigation task: an agent moves between two rooms through a doorway to reach a goal position. Success = reaching the goal pose, over 50 dataset-sampled start/goal pairs at eval seed 42.
| Run | Env / device | Success | Eval wall-clock | Status |
|---|---|---|---|---|
| Paper (LeWM) | authors, CUDA | ~87 | — | reference |
| Reporter (YushenZuo, #62) | released ckpt, CUDA | 90 | — | independent |
| Ours | transformers 4.57.6 · MPS | 86.0 (43/50) | 121 s | reproduced |
Failures were episodes 1, 3, 7, 17, 24, 31, 43.
2 · Visual results — reproduced episodes
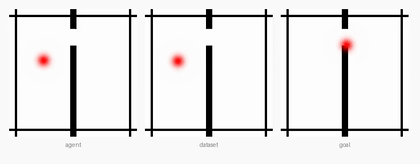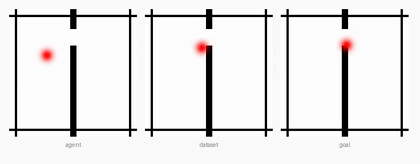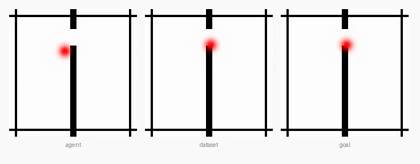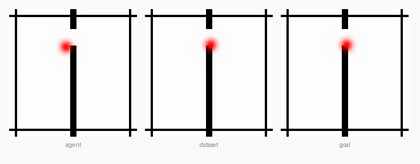
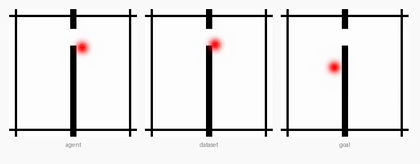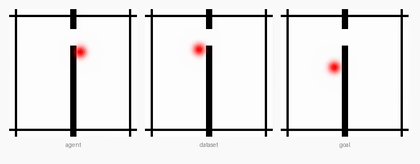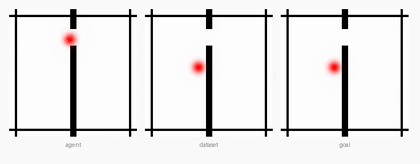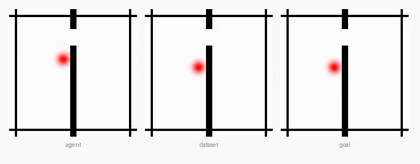
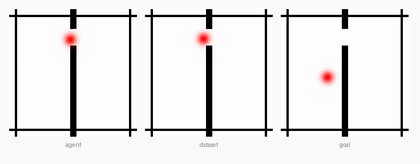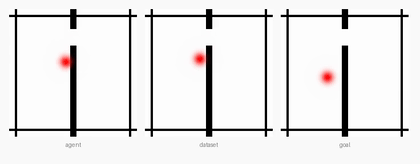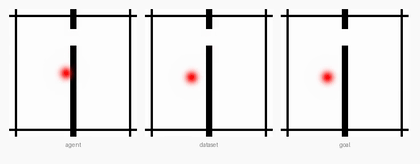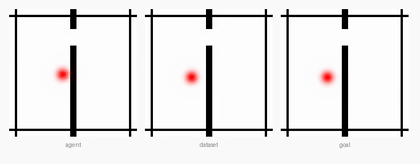
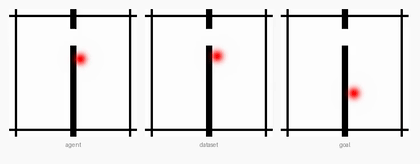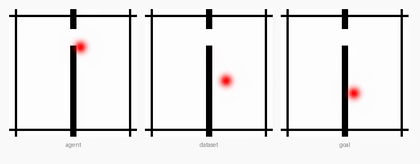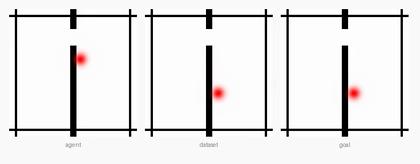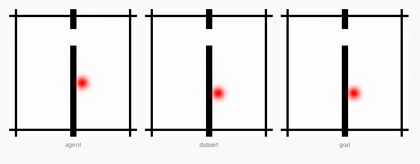
Actual rollouts written by eval.py (lewm_data/tworoom/env_*.mp4, re-encoded to GIF).
Each panel triplet shows current observation · replay · goal; the red agent navigates through the
doorway between the two rooms toward the goal position.
3 · Planning-time benchmark
Same official planner and CEM config as PushT (300 samples × 30 iters, horizon 5), so timing matches.
Per-plan (single env)
| Steady-state | ~2 s |
| Smoke (1 plan, 2 envs) | 3.8 s |
| CEM config | 300 × 30, H=5 |
Full 50-episode eval
| Total wall-clock | 121 s |
| Batched plan (50 envs) | ~20–82 s |
| Device | Apple MPS |
4 · Zero new fixes — the recipe generalizes
The only differences from the PushT run were the config name, checkpoint, and dataset. Every fix carried over unchanged, confirming they're general to all LeWM checkpoints, not PushT-specific:
transformers<5— same ViT key-rename issue (#68); checkpoint loads correctly under 4.57.6.hdf5plugin— required for thehdf5dataset format to register (#76).- Patched
eval.py— CUDA→device-aware (MPS);format="h5"→"hdf5".
Schema difference handled by the config itself: Two-Room has no state column, so
tworoom.yaml caches [action, proprio] and sets goal from proprio/goal_proprio.
No MuJoCo — Two-Room is pure 2D (pygame), like PushT.
5 · Reproduction recipe
# environment already prepared from the PushT run:
#   transformers==4.57.6, hdf5plugin, patched le-wm/eval.py

# dataset: tworoom.tar.zst (3.4 GB) -> tworoom.h5 (12 GB, 10,000 eps, 920,809 frames)
# from quentinll/lewm-tworooms  ·  symlinked into $STABLEWM_HOME
# checkpoint: quentinll/lewm-tworooms weights.pt + config.json

cd le-wm
STABLEWM_HOME=.../lewm_data SWM_DEVICE=mps PYTHONPATH=. \
  python eval.py --config-name=tworoom policy=tworoom/lewm \
  solver.device=mps +cache_dir=null eval.num_eval=50
# → {'success_rate': 86.0, ...}   in ~121 s
6 · Artifacts produced
| Artifact | What it is |
|---|---|
tworoom-baseline.html | This report |
tworoom_report_assets/ep_*.gif | 4 reproduced episodes (3 success + 1 failure) |
lewm_data/tworoom/env_0..49.mp4 | All 50 reproduced episode videos |
lewm_data/tworoom/tworoom_results.txt | Official metrics + evaluation_time |
le-wm/eval_tworoom.log | Run log (86%) |
lewm_data/tworoom.h5 | Symlink → 12 GB dataset on external scratch |
lewm_data/checkpoints/tworoom/lewm/ | weights.pt+config.json symlinks |
7 · Where this sits — 2 of 4 worlds
| World | Sim | Paper | Ours (MPS) | Status |
|---|---|---|---|---|
| PushT | pymunk | 96.0 ± 2.83 | 90.0 | reproduced |
| Two-Room | pygame | ~87 | 86.0 | reproduced |
| Reacher | dm_control / MuJoCo | ~86 | — | gated: MuJoCo-on-Mac |
| OGBench-Cube | ogbench / MuJoCo | ~74 | — | gated: MuJoCo-on-Mac |
Reacher & Cube need MUJOCO_GL=glfw on macOS (EGL is Linux-only) — slated for a later
pass, with a possible upstream contribution.
Reproduced on Apple Silicon (MPS) · LeWM JEPA 18.0M params · CEM 300×30, horizon 5 · eval seed 42 · June 3, 2026