LeWorldModel — Reacher Baseline Reproduction
Reproducing the official LeWM Reacher (dm_control) planning benchmark on Apple Silicon — the 4th and final world · June 4, 2026 · companions: PushT · Two-Room · Cube
Bottom line. The last world — and the hardest. Reacher (dm_control / MuJoCo) needed
two fixes beyond rendering, then reproduced at 76.0% (38/50) via the genuine
eval.py protocol on Apple Silicon (MPS). That's below the paper's ~86 and a
reporter's 80 — the biggest gap of the four, for two compounding reasons: the
glfw-vs-egl render-backend shift (shared with Cube) and Reacher being independently hard to reproduce
(a CUDA reporter already saw 80 vs 86, outside the paper's error bars).
1 · Task-completion results
Reacher is a 2-link arm that must move its fingertip to a target. Success uses the env's goal criterion, over 50 dataset-sampled start/goal pairs at eval seed 42.
| Run | Env / device | Success | Eval wall-clock | Status |
|---|---|---|---|---|
| Paper (LeWM) | authors, CUDA + egl | ~86 | — | reference |
| Reporter (YushenZuo, #62) | released ckpt, CUDA + egl | 80 outside error bars | — | independent |
| Ours | MPS + glfw + mujoco 3.8.1 | 76.0 (38/50) | 148 s | reproduced (largest gap) |
12 of 50 episodes failed. Reacher is the only world where even an independent CUDA reproducer fell outside the paper's reported error bars, so some of this gap predates the Mac port.
2 · Visual results — reproduced episodes
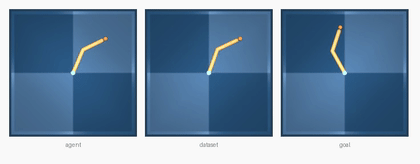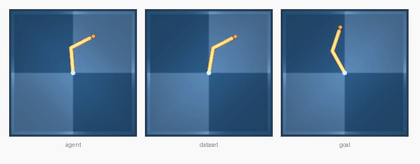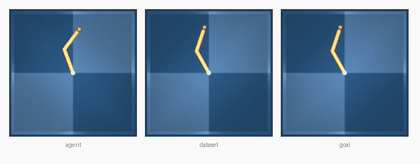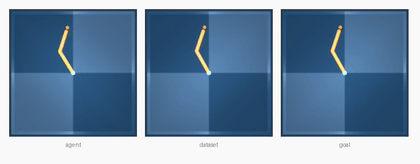
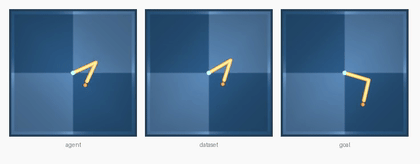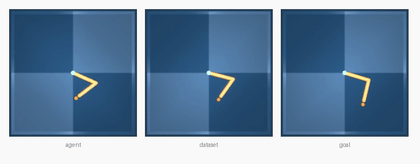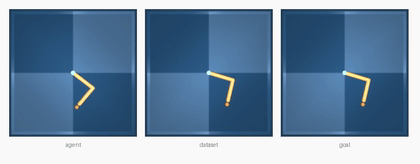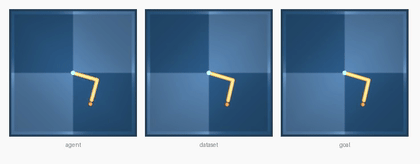
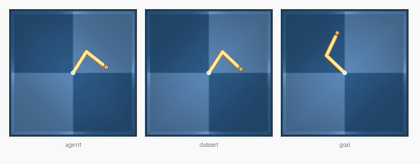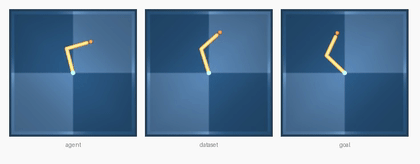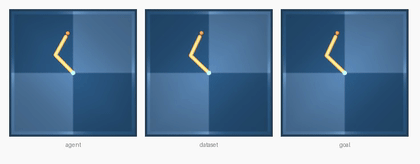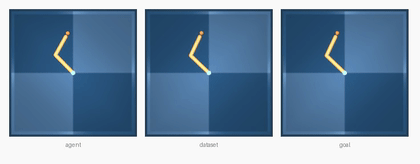
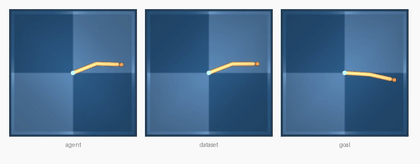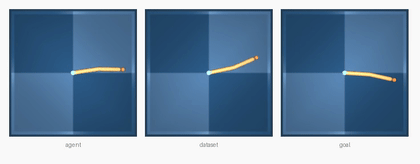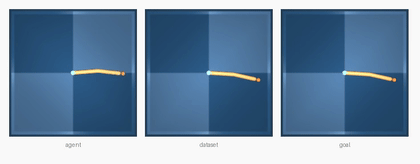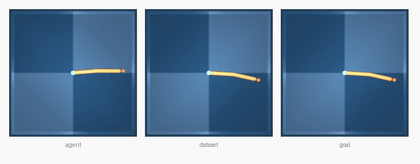
Actual rollouts written by eval.py (lewm_data/reacher/env_*.mp4, re-encoded to GIF).
Each panel triplet shows current observation · replay · goal; the 2-link arm swings its fingertip
toward the goal configuration.
3 · Two blockers, both dependency skews
Reacher was the only world that needed two fixes beyond the shared ones — both classic unpinned-dependency mismatches:
| Blocker | Error | Fix |
|---|---|---|
| MuJoCo render backend | ImportError: Unable to load EGL library | MUJOCO_GL=glfw on darwin (shared with Cube) |
| dm_control ↔ mujoco skew | AttributeError: 'MjModel' object has no attribute 'flex_bandwidth' | pip install mujoco==3.8.1 |
mujoco 3.9.0 removed the flex_bandwidth field that dm_control 1.0.41
introspects (it declares only mujoco>=3.8.1, so the breakage slips through). Pinning
mujoco==3.8.1 restores the field; ogbench/Cube only needs >=3.1.6, so it's unaffected.
With both fixes, 50-env parallel rendering works (verified pixels (50,1,224,224,3)).
4 · Why the −10 gap — render shift + an already-hard task
5 · Planning-time benchmark
Per-plan
| Smoke (1 plan, 2 envs) | 3.7 s |
| Batched (50 envs) | ~46–82 s |
| CEM config | 300 × 30, H=5 |
Full 50-episode eval
| Total wall-clock | 148 s |
| Render backend | glfw (CGL) |
| Device | Apple MPS |
6 · Reproduction recipe
# env: transformers==4.57.6, hdf5plugin, mujoco==3.8.1 (NOT 3.9.0), patched le-wm/eval.py
# eval.py sets MUJOCO_GL=glfw automatically on macOS

# dataset: reacher.tar.zst (22 GB) -> reacher.h5 (92 GB, 10,000 eps, 2.01M frames)
# from quentinll/lewm-reacher  ·  symlinked at $STABLEWM_HOME/dmc/reacher_random.h5
# checkpoint: quentinll/lewm-reacher weights.pt + config.json

cd le-wm
STABLEWM_HOME=.../lewm_data SWM_DEVICE=mps PYTHONPATH=. \
  python eval.py --config-name=reacher policy=reacher/lewm \
  solver.device=mps +cache_dir=null eval.num_eval=50
# → {'success_rate': 76.0, ...}   in ~148 s
7 · Artifacts produced
| Artifact | What it is |
|---|---|
reacher-baseline.html | This report |
reacher_report_assets/ep_*.gif | 4 reproduced episodes (3 success + 1 failure) |
lewm_data/reacher/env_0..49.mp4 | All 50 reproduced episode videos |
lewm_data/reacher/dmc_results.txt | Official metrics + evaluation_time |
le-wm/eval_reacher.log | Run log (76%) |
env: mujoco==3.8.1 | The dm_control compatibility fix (down from 3.9.0) |
lewm_data/dmc/reacher_random.h5 | Symlink → 92 GB dataset on external scratch |
lewm_data/checkpoints/reacher/lewm/ | weights.pt+config.json symlinks |
8 · Benchmark complete — all 4 worlds
| World | Sim | Paper | Ours (MPS) | Gap | Status |
|---|---|---|---|---|---|
| PushT | pymunk (CPU) | 96.0 ± 2.83 | 90.0 | −6 | reproduced |
| Two-Room | pygame (CPU) | ~87 | 86.0 | −1 | reproduced |
| OGBench-Cube | ogbench / MuJoCo | ~74 | 66.0 | −8 | render gap |
| Reacher | dm_control / MuJoCo | ~86 | 76.0 | −10 | render gap |
Fixes needed to reproduce the released checkpoints from a clean install, all documented upstream:
transformers<5 (#80),
MUJOCO_GL=glfw on macOS (#81),
mujoco==3.8.1 for dm_control, and hdf5plugin.
Reproduced on Apple Silicon (MPS, glfw render, mujoco 3.8.1) · LeWM JEPA 18.0M params · CEM 300×30, horizon 5 · eval seed 42 · June 4, 2026